• Produktbild: Social Robotics
  • Produktbild: Social Robotics
- 21%

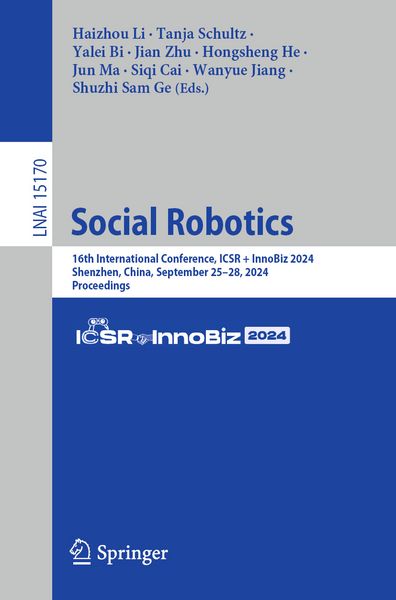
Social Robotics 16th International Conference, ICSR + InnoBiz 2024, Shenzhen, China, September 25–28, 2024, Proceedings

21% sparen

64,99 € UVP 82,49 €

inkl. gesetzl. MwSt., Versandkostenfrei


Beschreibung

Produktdetails

Einband

Taschenbuch

Erscheinungsdatum

07.02.2025

Abbildungen

XIV, 368 p. 122 illus., 111 illus. in color.

Herausgeber

Haizhou Li + weitere

Verlag

Springer Singapore

Seitenzahl

368

Maße (L/B/H)

23,5/15,5/2,1 cm

Gewicht

581 g

Auflage

1. Auflage

Sprache

Englisch

ISBN

978-981-9611-50-8

Beschreibung

Produktdetails

Einband

Taschenbuch

Erscheinungsdatum

07.02.2025

Abbildungen

XIV, 368 p. 122 illus., 111 illus. in color.

Herausgeber

Verlag

Springer Singapore

Seitenzahl

368

Maße (L/B/H)

23,5/15,5/2,1 cm

Gewicht

581 g

Auflage

1. Auflage

Sprache

Englisch

ISBN

978-981-9611-50-8

Herstelleradresse

Springer-Verlag KG
Sachsenplatz 4-6
1201 Wien
AT

Email: ProductSafety@springernature.com

Noch keine Bewertungen vorhanden

Verfassen Sie die erste Bewertung zu diesem Artikel

Helfen Sie anderen Kundinnen und Kunden durch Ihre Meinung.

Kundinnen und Kunden meinen

Bewertungen (0)

  • Produktbild: Social Robotics
  • Produktbild: Social Robotics

  • .- Diverse Gaussian Sampling for Human Motion Prediction.


    .- Multi-Scale Separable Convolution and Dilated Attention for Machinery Fault Diagnosis.


    .- SegmentAnything-Based Approach to Scene Understanding and Grasp Generation.


    .- Content-Aware Efficient Learner for Audio-Visual Emotion Recognition.


    .- The Impact of Synchronized Visual and Auditory Attention on Human Perception.


    .- CollectiveSFT: Scaling Large Language Models for Chinese Medical Benchmark with Collective Instructions in Healthcare.


    .- A New Multi-Axis Force Sensor for Measuring the Wheel-Terrain Interaction ahead of the Robotic Vehicles.


    .- Potential-field-based Motion Planning for Social Robots by Adapting Social Conventions.


    .- Parametrically-Designed Artificial Hand with Multifunctional Grasps.


    .- Tolerant Tracking Control Protocol for PMSM Based on Policy Iteration Algorithm and Fault Compensation.


    .- ROOTED: an Open Source Toolkit for Dialogue Systems in Human Robot Interaction.


    .- Educational-Psychological Dialogue Robot Based on Multi-Agent Collaboration.


    .- Human-Robot Pose Tracking Based on CNN with Color and Geometry Aggregation.


    .- Cued Speech-Integrated Audio-Visual Variational Autoencoder for Speech Enhancement.


    .- Semi-Supervised Speaker Localization with Gaussian-like Pseudo-labeling.


    .- MCCS: The First Open Multi-Cuer Mandarin Chinese Cued Speech Dataset and Benchmark.


    .- A Review of Human Mesh Reconstruction: Beyond 2D Video Object Segmentation.


    .- A Transformer-based Depression Detection Network Leveraging Speech Emotional Expression Cues.


    .- Am I a social buddy? A literature review on socially appealing design and implementation methods for social robots.


    .- Optimization-based Trajectory Planning for Autonomous Ground Vehicles.


    .- Alzheimer's disease detection based on large language model prompt  engineering.


    .- Mapless Navigation in Factory Environments with Safe RL Approach.


    .- Video Question Answering Based on Audio-Visual Hyper Graphs.


    .- Synergized Twin Layer for Federated Action Recognition.


    .- Controllable Talking Head Synthesis by Equivariant Data Augmentation for Spatial Coordinates.


    .- Multi-Source-Domain Adaptation for TMS-EEG based Depression Detection.


    .- Structured Dialogue System for Mental Health: An LLM Chatbot Leveraging the PM+ Guidelines.


    .- Feature Extraction Method Based on Contrastive Learning for Dysarthria Detection.


    .- Flying Together with Audio and Video: Enhancing Communication for the Hearing-impaired Through an Emerging Closed Captioning Standard.


    .- FARD: Fully Automated Railway Anomaly Detection System.


    .- M-Vec: Matryoshka Speaker Embeddings with Flexible Dimensions.


    .- Complex instructions translation using fine-tuned Large Language Models.


    .- Autonomous Multi-Robot Action Planning through Controlled Robot Language.


    .- Omnisurface: Common Reality for Intuitive Human-Robot Collaboration.


    .- Grasp Intention Interpretation in Object Handover for Human-Robot Teaming.


    .- Leader-Follower Formation of a Car-like Robot Using ROS and Trajectory Tracking.