KI-Beratung Beta

  • Produktbild: Wang, J: Cooperative Control of Multi-Agent Systems
  • Produktbild: Wang, J: Cooperative Control of Multi-Agent Systems

Wang, J: Cooperative Control of Multi-Agent Systems

162,99 €

inkl. gesetzl. MwSt., Versandkostenfrei


Beschreibung

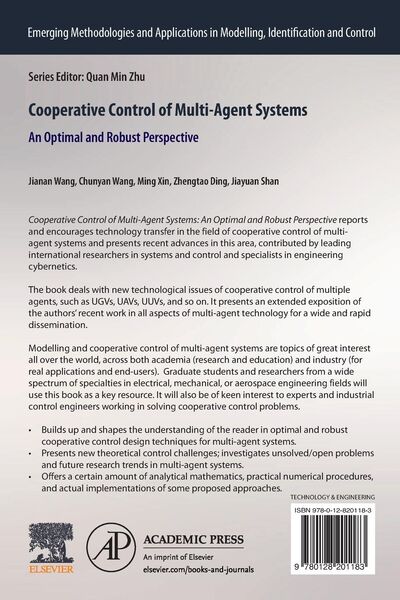
Cooperative Control of Multi-Agent Systems: An Optimal and Robust Perspective reports and encourages technology transfer in the field of cooperative control of multi-agent systems. The book deals with UGVs, UAVs, UUVs and spacecraft, and more. It presents an extended exposition of the authors' recent...

Beschreibung

Cooperative Control of Multi-Agent Systems: An Optimal and Robust Perspective reports and encourages technology transfer in the field of cooperative control of multi-agent systems. The book deals with UGVs, UAVs, UUVs and spacecraft, and more. It presents an extended exposition of the authors' recent work on all aspects of multi-agent technology. Modelling and cooperative control of multi-agent systems are topics of great interest, across both academia (research and education) and industry (for real applications and end-users). Graduate students and researchers from a wide spectrum of specialties in electrical, mechanical or aerospace engineering fields will use this book as a key resource.

Rezension

"....In summary, the book reports some of the latest advances in the cooperative control design for multi-agent systems, from an optimality and robustness perspective. It covers a wide range of applications, such as rendezvous, cooperative tracking, formation flying and flocking, etc. In each chapter, rich simulations and examples are provided to help researchers from both academia and industry use optimal and robust methods in multiagent control. The book will serve as a useful reference in multi-agent control theory." --MathSciNet

Produktdetails

Einband

Taschenbuch

Erscheinungsdatum

26.03.2020

Verlag Elsevier Science & Technology
Seitenzahl

260

Produktdetails

Einband

Taschenbuch

Erscheinungsdatum

26.03.2020

Verlag Elsevier Science & Technology
Seitenzahl

260

Maße (L/B/H)

22,9/15,2/1,4 cm

Gewicht

354 g

Sprache

Englisch

ISBN

978-0-12-820118-3

EU-Ansprechpartner

Elsevier B.V.
Radarweg 29
1043 NX Amsterdam
NL
productsafety@elsevier.com

Herstelleradresse

Elsevier Science & Technology
London Wall 125
EC2Y 5AS London
GB
tradeorders@elsevier.com

Noch keine Bewertungen vorhanden

Verfassen Sie die erste Bewertung zu diesem Artikel

Helfen Sie anderen Kundinnen und Kunden durch Ihre Meinung.

Kundinnen und Kunden meinen

Bewertungen (0)

Die Leseprobe wird geladen.
  • Produktbild: Wang, J: Cooperative Control of Multi-Agent Systems
  • Produktbild: Wang, J: Cooperative Control of Multi-Agent Systems
  • Part One - About Cooperative Control
    1. Introduction
    2. Preliminaries

    Part Two - Optimal Cooperative Control
    3. Optimal consensus control of multiple integrator systems
    4. Optimal cooperative tracking and flocking of multi-agent systems
    5. Optimal formation control of multiple UAVs
    6. Optimal coverage control of multi-robot systems

    Part Three - Robust Cooperative Control
    7. Robust consensus control of multi-agent systems with input delay
    8. Robust consensus control of multi-agent systems with disturbance rejection
    9. Robust consensus control nonlinear p-order integrator systems
    10. Robust cooperative control of networked negative-imaginary systems