KI-Beratung Beta

Gutscheinbedingungen

**Gültig am 15.10.2026 auf Spielzeug, Schreibwaren, Filme, Geschenke & Trends, Musik, tolino eReader & Zubehör, Hörbücher und Hörbuch-Downloads, nicht preisgebundene Bücher und Kalender in der Thalia App. Einzelne Artikel können ausgeschlossen sein. Aufgrund der Buchpreisbindung sind deutschsprachige Bücher und eBooks ausgenommen. Zusätzlich ausgenommen sind Abos & Flatrates, Games, Geschenkkarten/-boxen, Shelfies, Software, Zeitschriften sowie einzelne Artikel von tonies®. Pro Einkauf einmal einlösbar. Click & Collect nur bei Onlinevorabzahlung möglich. Keine Barauszahlung. Nicht kombinierbar mit anderen Aktionen und Gutscheinen. Gutschein wird auf max. 500€ Bestellwert angerechnet. Nicht gültig für Versandkosten und Services.

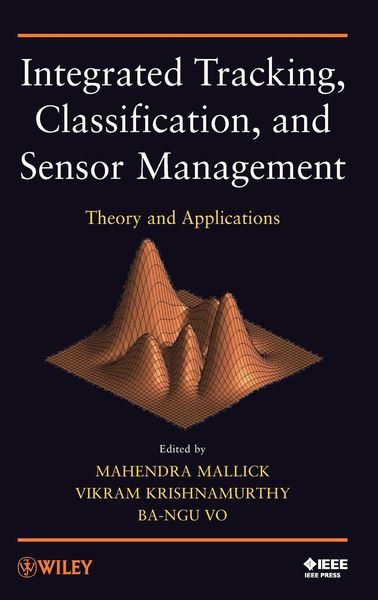
  • Produktbild: Integrated Tracking, Classification, and Sensor Management
  • Produktbild: Integrated Tracking, Classification, and Sensor Management

Integrated Tracking, Classification, and Sensor Management

203,99 €

inkl. gesetzl. MwSt., Versandkostenfrei


Beschreibung

Produktdetails

Einband

Gebundene Ausgabe

Erscheinungsdatum

13.11.2012

Abbildungen

Photos: 50 B&W, 0 Color; Drawings: 20 B&W, 0 Color; Tables: 0 B&W, 0 Color; Graphs: 50 B&W, 0 Color

Herausgeber

Ba-Ngu Vo + weitere

Verlag

John Wiley & Sons

Seitenzahl

736

Maße (L/B/H)

24/16,1/4,4 cm

Gewicht

1261 g

Auflage

1. Auflage

Sprache

Englisch

ISBN

978-0-470-63905-4

Beschreibung

Produktdetails

Einband

Gebundene Ausgabe

Erscheinungsdatum

13.11.2012

Abbildungen

Photos: 50 B&W, 0 Color; Drawings: 20 B&W, 0 Color; Tables: 0 B&W, 0 Color; Graphs: 50 B&W, 0 Color

Herausgeber

Verlag

John Wiley & Sons

Seitenzahl

736

Maße (L/B/H)

24/16,1/4,4 cm

Gewicht

1261 g

Auflage

1. Auflage

Sprache

Englisch

ISBN

978-0-470-63905-4

Herstelleradresse

Libri GmbH
Europaallee 1
36244 Bad Hersfeld
DE

Email: gpsr@libri.de

Noch keine Bewertungen vorhanden

Verfassen Sie die erste Bewertung zu diesem Artikel

Helfen Sie anderen Kundinnen und Kunden durch Ihre Meinung.

Kundinnen und Kunden meinen

Bewertungen (0)

Die Leseprobe wird geladen.
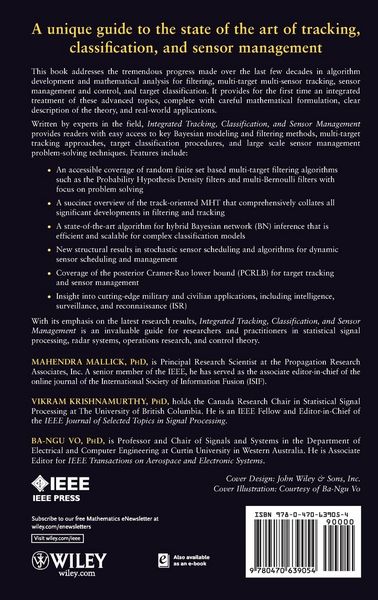
  • Produktbild: Integrated Tracking, Classification, and Sensor Management
  • Produktbild: Integrated Tracking, Classification, and Sensor Management
  • PREFACE xvii
     
    CONTRIBUTORS xxiii
     
    PART I FILTERING
     
    1. Angle-Only Filtering in Three Dimensions 3
    Mahendra Mallick, Mark Morelande, Lyudmila Mihaylova, Sanjeev Arulampalam, and Yanjun Yan
     
    1.1 Introduction 3
     
    1.2 Statement of Problem 6
     
    1.3 Tracker and Sensor Coordinate Frames 6
     
    1.4 Coordinate Systems for Target and Ownship States 7
     
    1.5 Dynamic Models 9
     
    1.6 Measurement Models 14
     
    1.7 Filter Initialization 15
     
    1.8 Extended Kalman Filters 17
     
    1.9 Unscented Kalman Filters 19
     
    1.10 Particle Filters 23
     
    1.11 Numerical Simulations and Results 28
     
    1.12 Conclusions 31
     
    2. Particle Filtering Combined with Interval Methods for Tracking Applications 43
    Amadou Gning, Lyudmila Mihaylova, Fahed Abdallah, and Branko Ristic
     
    2.1 Introduction 43
     
    2.2 Related Works 44
     
    2.3 Interval Analysis 46
     
    2.4 Bayesian Filtering 51
     
    2.5 Box Particle Filtering 52
     
    2.6 Box Particle Filtering Derived from the Bayesian Inference Using a Mixture of Uniform Probability Density Functions 56
     
    2.7 Box-PF Illustration over a Target Tracking Example 65
     
    2.8 Application for a Vehicle Dynamic Localization Problem 67
     
    2.9 Conclusions 71
     
    3. Bayesian Multiple Target Filtering Using Random Finite Sets 75
    Ba-Ngu Vo, Ba-Tuong Vo, and Daniel Clark
     
    3.1 Introduction 75
     
    3.2 Overview of the Random Finite Set Approach to Multitarget Filtering 76
     
    3.3 Random Finite Sets 81
     
    3.4 Multiple Target Filtering and Estimation 85
     
    3.5 Multitarget Miss Distances 91
     
    3.6 The Probability Hypothesis Density (PHD) Filter 95
     
    3.7 The Cardinalized PHD Filter 105
     
    3.8 Numerical Examples 111
     
    3.9 MeMBer Filter 117
     
    4. The Continuous Time Roots of the Interacting Multiple Model Filter 127
    Henk A.P. Blom
     
    4.1 Introduction 127
     
    4.2 Hidden Markov Model Filter 129
     
    4.3 System with Markovian Coefficients 136
     
    4.4 Markov Jump Linear System 141
     
    4.5 Continuous-Discrete Filtering 149

    4.6 Concluding Remarks 154
     
    PART II MULTITARGET MULTISENSOR TRACKING
     
    5. Multitarget Tracking Using Multiple Hypothesis Tracking 165
    Mahendra Mallick, Stefano Coraluppi, and Craig Carthel
     
    5.1 Introduction 165
     
    5.2 Tracking Algorithms 166
     
    5.3 Track Filtering 170
     
    5.4 MHT Algorithms 179
     
    5.5 Hybrid-State Derivations of MHT Equations 180
     
    5.6 The Target-Death Problem 185
     
    5.7 Examples for MHT 186
     
    5.8 Summary 189
     
    6. Tracking and Data Fusion for Ground Surveillance 203
    Michael Mertens, Michael Feldmann, Martin Ulmke, and Wolfgang Koch
     
    6.1 Introduction to Ground Surveillance 203
     
    6.2 GMTI Sensor Model 204
     
    6.3 Bayesian Approach to Ground Moving Target Tracking 209
     
    6.4 Exploitation of Road Network Data 222
     
    6.5 Convoy Track Maintenance Using Random Matrices 234
     
    6.6 Convoy Tracking with the Cardinalized Probability Hypothesis Density Filter 243
     
    7. Performance Bounds for Target Tracking: Computationally Efficient Formulations and Associated Applications 255
    Marcel Hernandez
     
    7.1 Introduction 255
     
    7.2 Bayesian Performance Bounds 258
     
    7.3 PCRLB Formulations in Cluttered Environments 262
     
    7.4 An Approximate PCRLB for Maneuevring Target Tracking 269
     
    7.5 A General Framework for the Deployment of Stationary Sensors 271
     
    7.6 UAV Trajectory Planning 294
     
    7.7 Summary and Conclusions 305
     
    8. Track-Before-De