KI-Beratung Beta

Gutscheinbedingungen

**Gültig bis 09.11.2026 auf tolino shine color (4016621130473), tolino vision color (4016621130183) und tolino vision color weiß (4016621131456) online auf thalia.at, in der Thalia App und in allen Thalia Buchhandlungen in Österreich. In den Buchhandlungen nur gültig auf lagernde Ware. Pro Einkauf einmal einlösbar. Nur gültig gegen Vorlage oder im Onlineshop hinterlegter Bonuscard. Infos zur Einlösung in der Buchhandlung sind auf der Bonuscard-Vorteilspreisseite zu finden. Click & Collect nur bei Onlinevorabzahlung möglich. Keine Einlösung bei Scan & Go-Bezahlung. Keine Barauszahlung. Nicht kombinierbar mit anderen Aktionen und Gutscheinen. Nicht gültig für Geschenkkarten, Versandkosten und Services. Nur solange der Vorrat reicht.

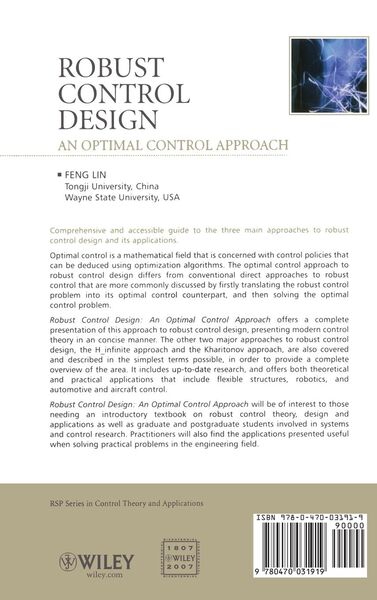
  • Produktbild: Robust Control Design: An Optimal Control Approach
  • Produktbild: Robust Control Design: An Optimal Control Approach

Robust Control Design: An Optimal Control Approach

203,99 €

inkl. gesetzl. MwSt., Versandkostenfrei


Beschreibung

Produktdetails

Einband

Gebundene Ausgabe

Erscheinungsdatum

18.09.2007

Verlag

WILEY

Seitenzahl

384

Maße (L/B/H)

23,5/15,7/2,5 cm

Gewicht

702 g

Sprache

Englisch

ISBN

978-0-470-03191-9

Beschreibung

Produktdetails

Einband

Gebundene Ausgabe

Erscheinungsdatum

18.09.2007

Verlag

WILEY

Seitenzahl

384

Maße (L/B/H)

23,5/15,7/2,5 cm

Gewicht

702 g

Sprache

Englisch

ISBN

978-0-470-03191-9

Herstelleradresse

Libri GmbH
Europaallee 1
36244 Bad Hersfeld
DE

Email: gpsr@libri.de

Noch keine Bewertungen vorhanden

Verfassen Sie die erste Bewertung zu diesem Artikel

Helfen Sie anderen Kundinnen und Kunden durch Ihre Meinung.

Kundinnen und Kunden meinen

Bewertungen (0)

  • Produktbild: Robust Control Design: An Optimal Control Approach
  • Produktbild: Robust Control Design: An Optimal Control Approach
  • Preface.

    Notation.

    1 Introduction.

    1.1 Systems and Control

    1.2 Modern Control Theory

    1.3 Stability

    1.4 Optimal Control

    1.5 Optimal Control Approach

    1.6 Kharitonov Approach

    1.7 H_ and H2 Control

    1.8 Applications

    1.9 Use of This Book

    2 Fundamentals of Control Theory.

    2.1 State Space Model

    2.2 Responses of Linear Systems

    2.3 Similarity Transformation

    2.4 Controllability and Observability

    2.5 Pole Placement by State Feedback

    2.6 Pole Placement Using Observer

    2.7 Notes and References

    2.8 Problems

    3 Stability Theory.

    3.1 Stability and Lyapunov Theorem

    3.2 Linear Systems

    3.3 Routh-Hurwitz Criterion

    3.4 Nyquist Criterion

    3.5 Stabilizability and Detectability

    3.6 Notes and References

    3.7 Problems

    4 Optimal Control and Optimal Observers.

    4.1 Optimal Control Problem

    4.2 Principle of Optimality

    4.3 Hamilton-Jacobi-Bellman Equation

    4.4 Linear Quadratic Regulator Problem

    4.5 Kalman Filter

    4.6 Notes and References

    4.7 Problems 

    5  Robust Control of Linear Systems.

    5.1 Introduction

    5.2 Matched Uncertainty

    5.3 Unmatched Uncertainty

    5.4 Uncertainty in the Input Matrix

    5.5 Notes and References

    5.6 Problems

    6 Robust Control of Nonlinear Systems.

    6.1 Introduction

    6.2 Matched Uncertainty

    6.3 Unmatched Uncertainty

    6.4 Uncertainty in the Input Matrix

    6.5 Notes and References

    6.6 Problems

    7 Kharitonov Approach.

    7.1 Introduction

    7.2 Preliminary Theorems

    7.3 Kharitonov Theorem

    7.4 Control Design Using Kharitonov Theorem

    7.5 Notes and References

    7.6 Problems

    8 H and H2 Control.

    8.1 Introduction

    8.2 Function Space

    8.3 Computation of H2 and H_ Norms

    8.4 Robust Control Problem as H2 and H_ Control

    Problem

    8.5 H2/H_ Control Synthesis

    8.6 Notes and References

    8.7 Problems

    9 Robust Active Damping.

    9.1 Introduction

    9.2 Problem Formulation

    9.3 Robust Active Damping Design

    9.4 Active Vehicle Suspension System

    9.5 Discussion

    9.6 Notes and References

    10 Robust Control of Manipulators.

    10.1 Robot Dynamics

    10.2 Problem Formulation

    10.3 Robust Control Design

    10.4 Simulations

    10.5 Notes and References

    11 Aircraft Hovering Control.

    11.1 Modelling and Problem Formulation

    11.2 Control Design for Jet-borne Hovering 

    11.3 Simulation

    11.4 Notes and References

    Appendix A: Mathematical Modelling of Physical Systems.

    References and Bibliography.

    Index.